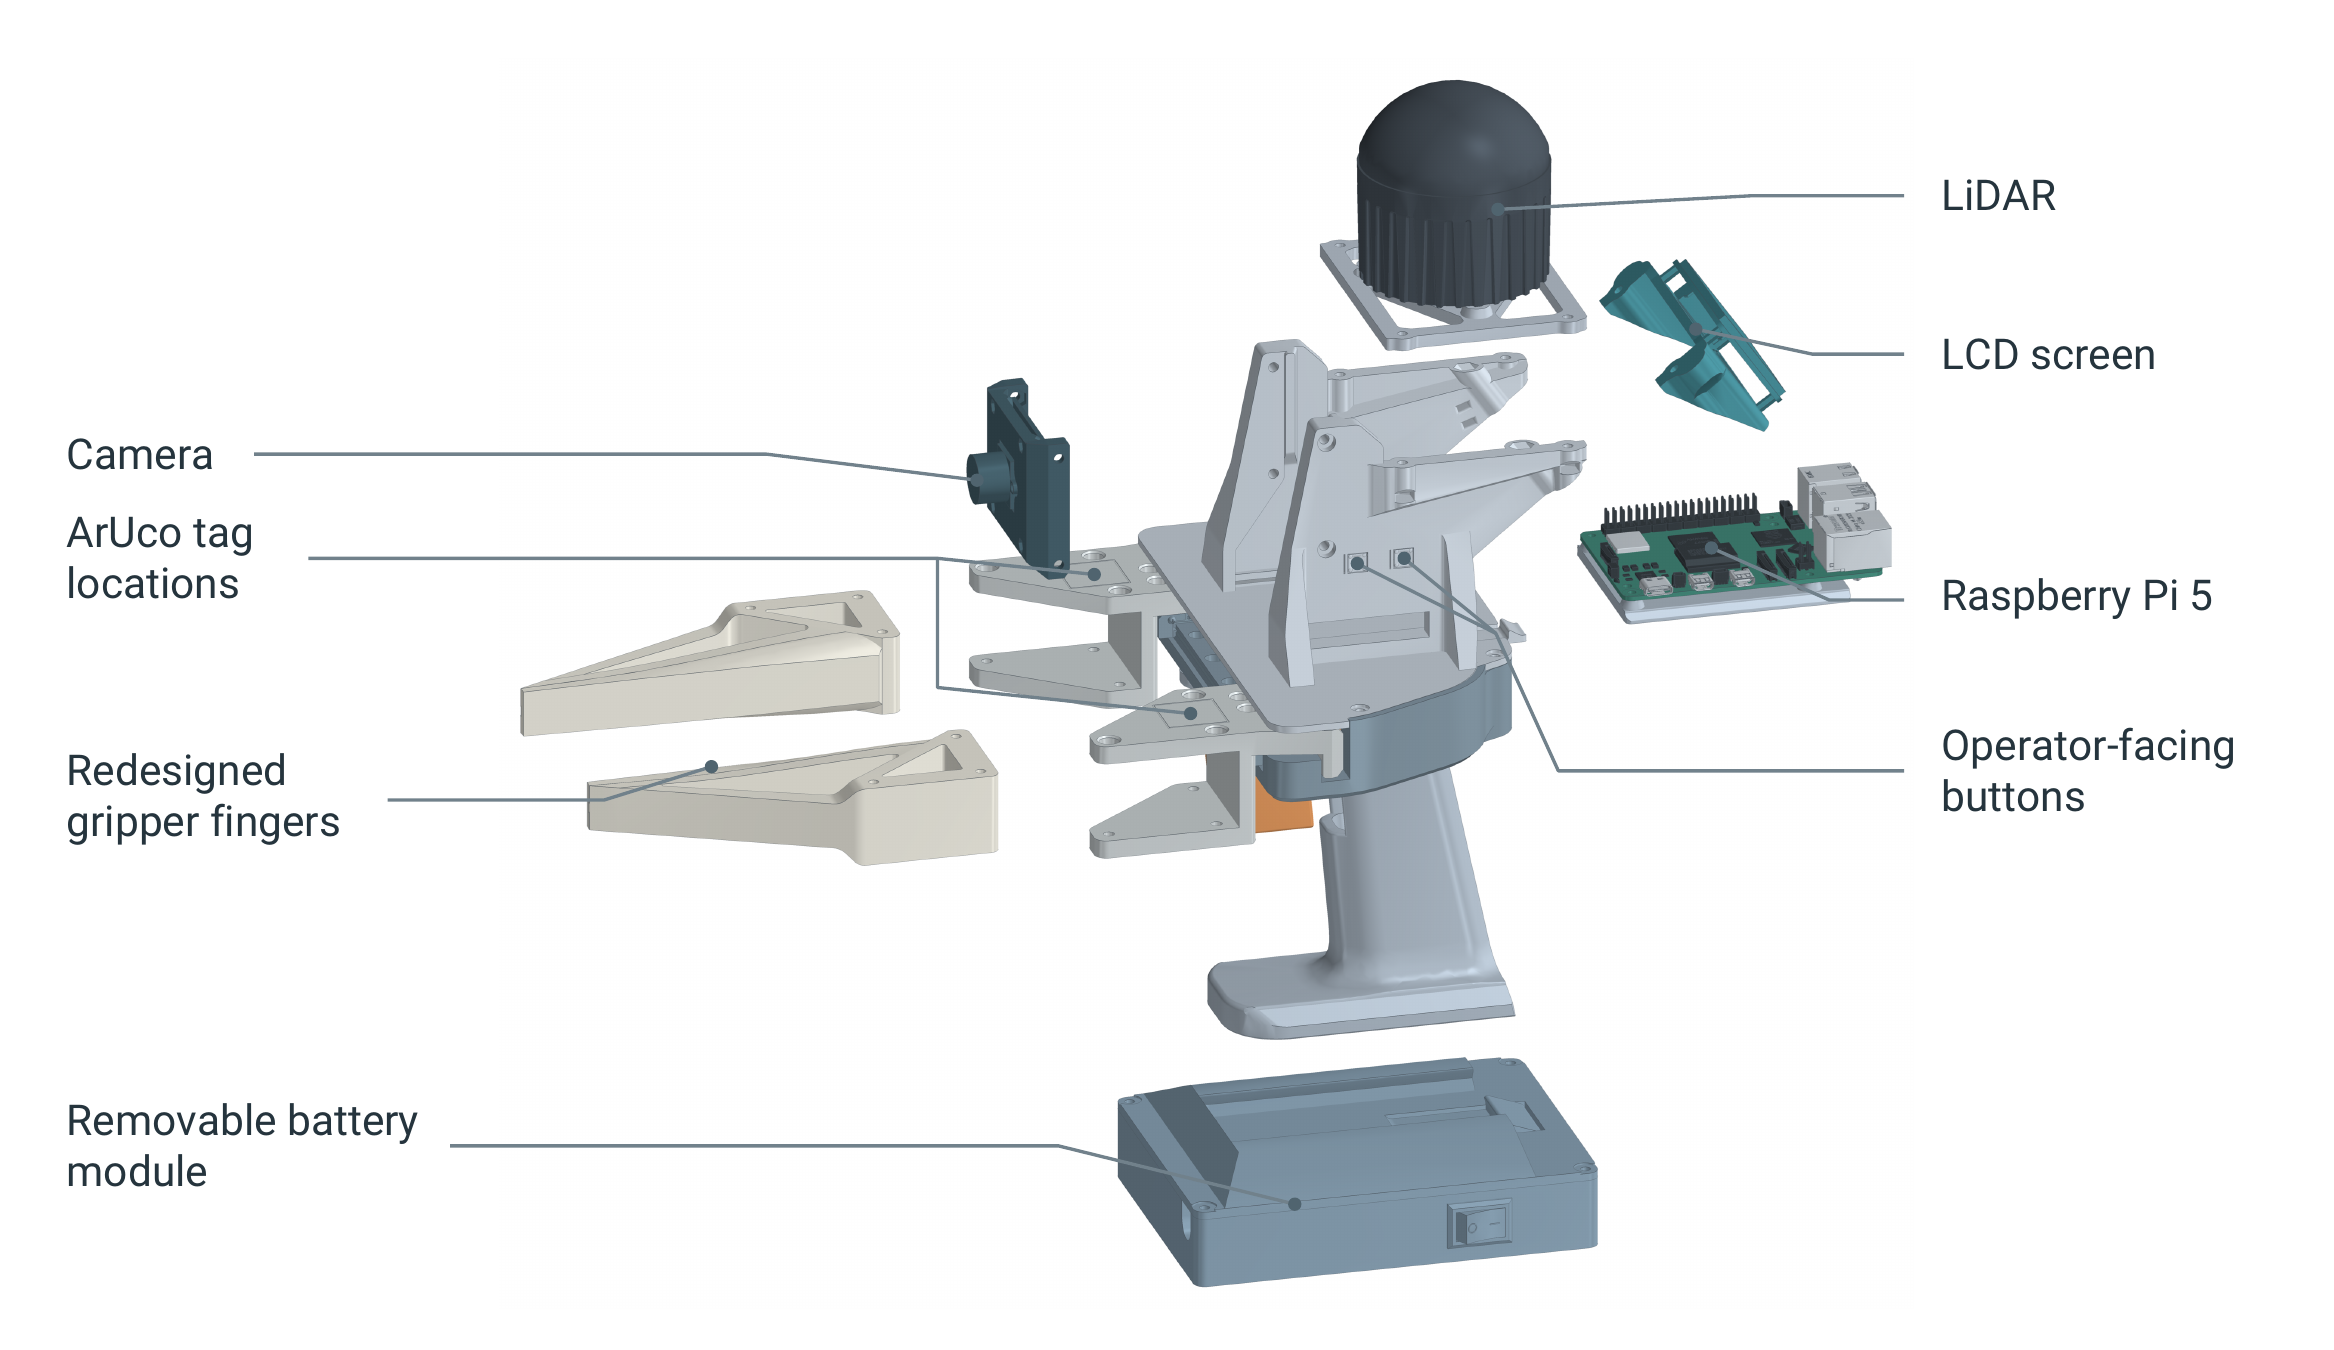
Handheld Universal Manipulation Interface (UMI) devices let human experts demonstrate tasks directly. Preparing these demonstrations for learning still requires consistent hardware, calibration, and data processing. We present UMI-Live, a bimanual hardware and software system for in-the-wild collection and robot learning. Each gripper integrates camera and LiDAR–inertial sensing, onboard compute, and power, without external tracking equipment or calibration of the collection environment.
A single button controls recording while an asynchronous pipeline performs parallel and batched reconstruction and publishes validated LeRobot datasets. We evaluate π0.5 and MolmoAct2 on placing six oranges in a bowl, with up to 10/10 and 8/10 successful trials, respectively. We release approximately 40 hours across three tasks and plan to release hardware designs, software, and reproduction guides at the project repository.