UMI-Live for In-The-Wild Bimanual Robotics Data Collection

Govind Velamoor1,*, Adrian Lin2,*, Sam Jung3, Spencer Mateega3, Brandon Y. Yang4,‡, Amish Sethi5,†
1Yale University, 2Carnegie Mellon University, 3AfterQuery, 4University of Pennsylvania, 5Harvard University
* Equal first-author contribution. ‡ Equal advising. † Corresponding author.

Abstract

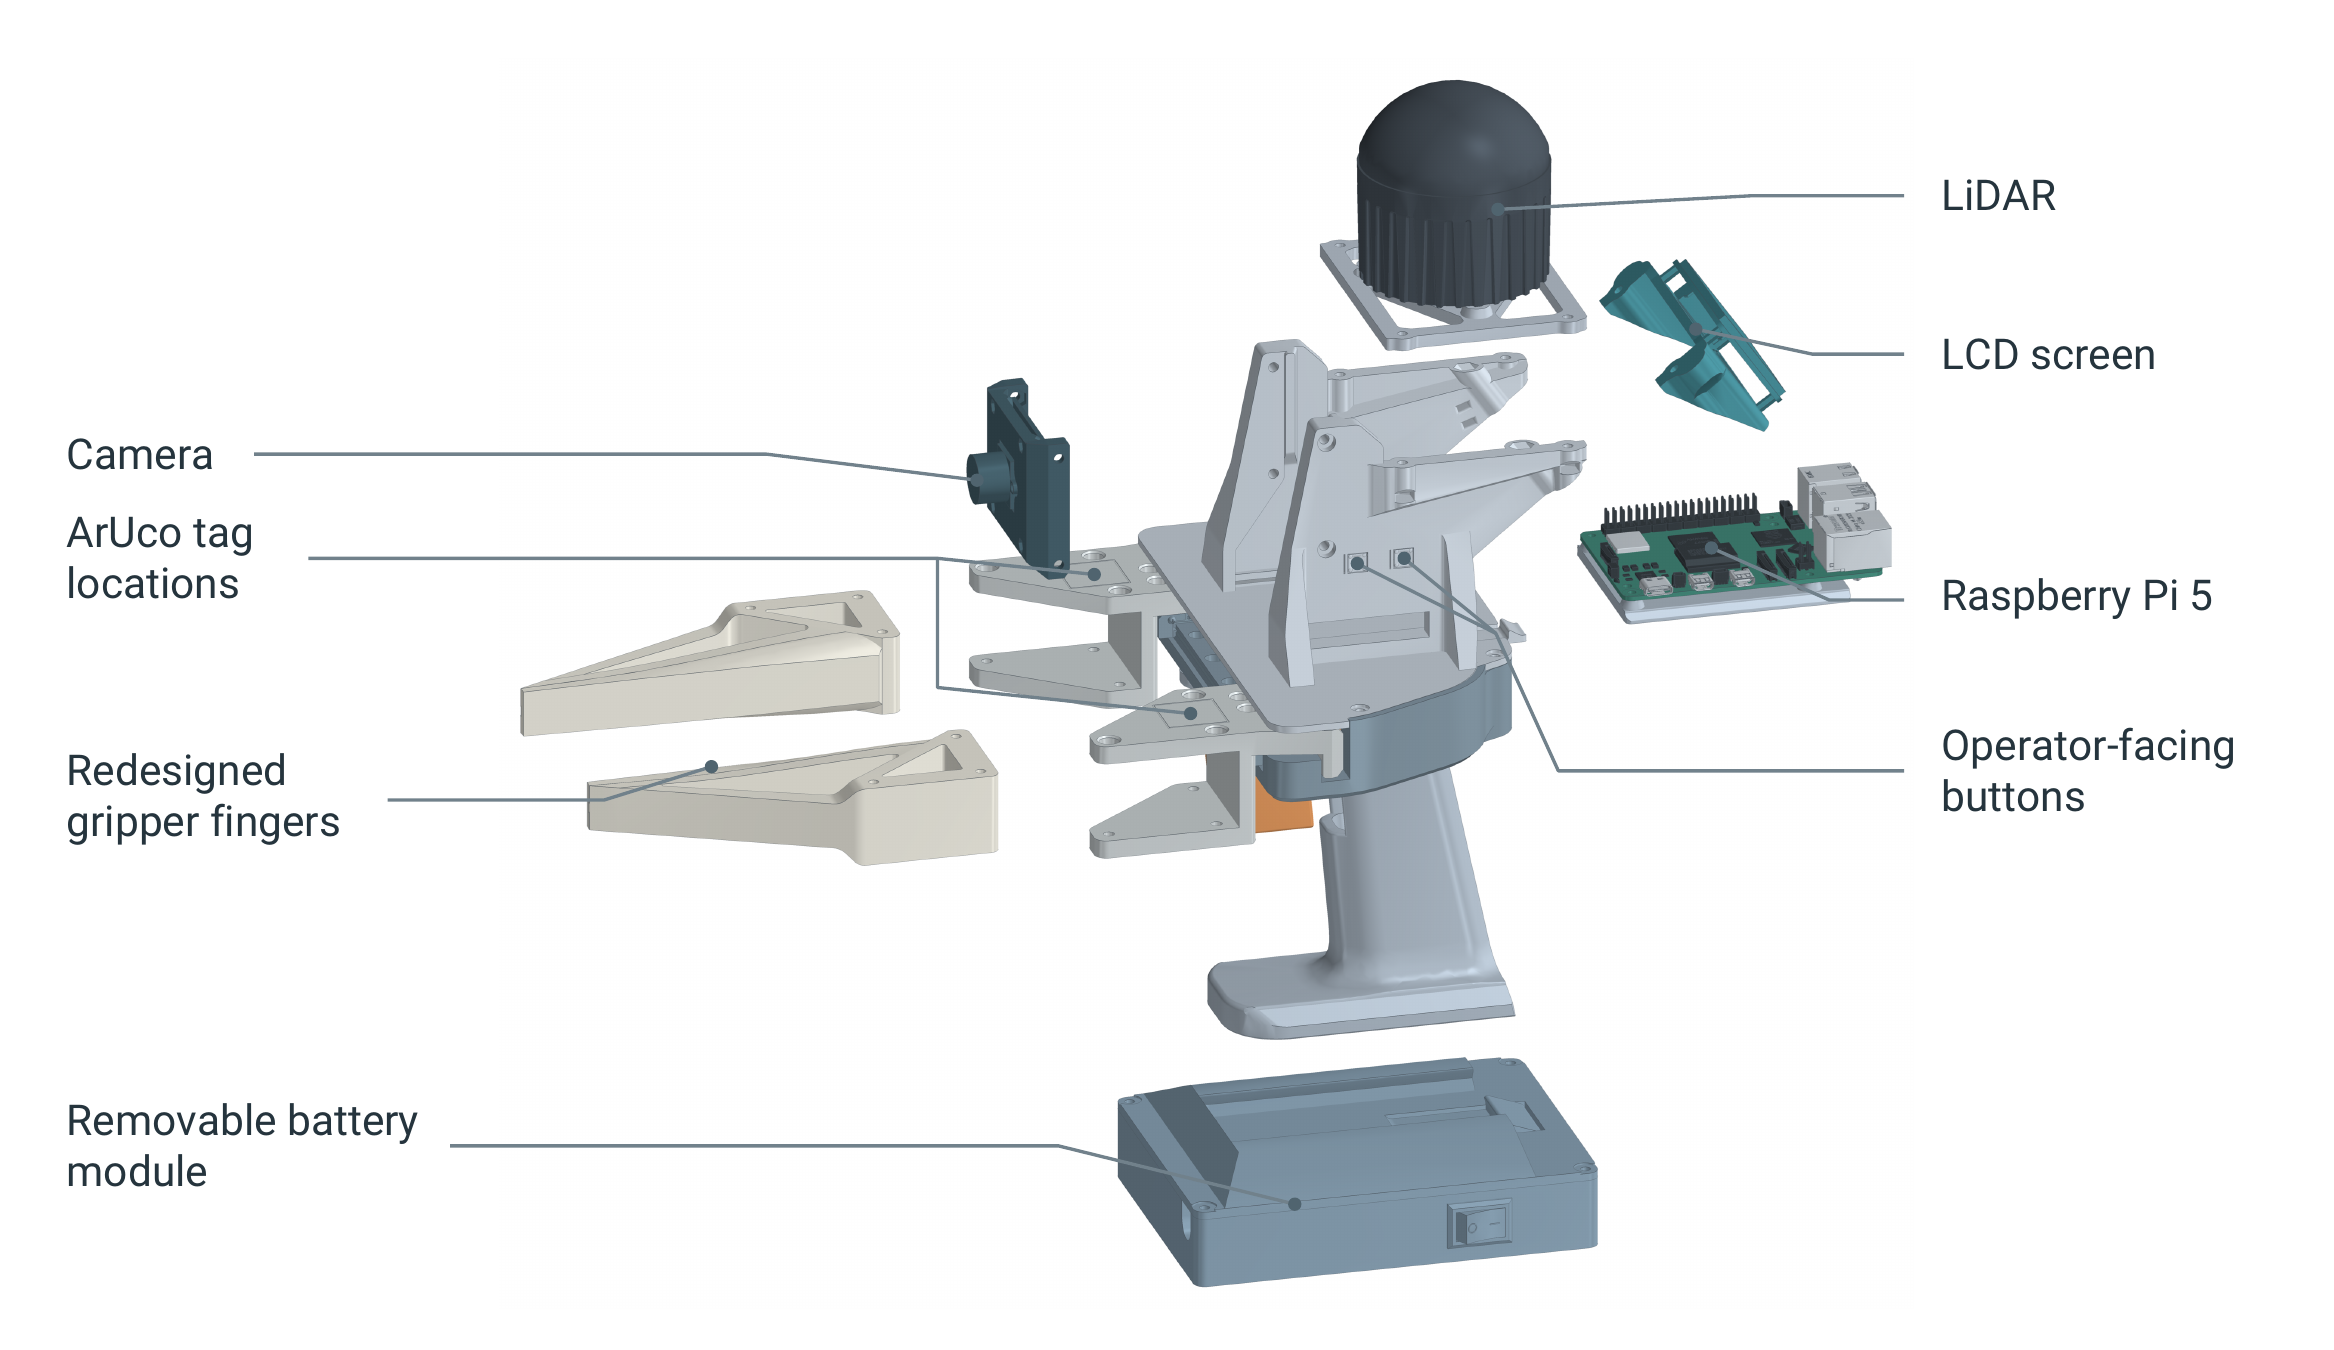
Handheld Universal Manipulation Interface (UMI) devices let human experts demonstrate tasks directly. Preparing these demonstrations for learning still requires consistent hardware, calibration, and data processing. We present UMI-Live, a bimanual hardware and software system for in-the-wild collection and robot learning. Each gripper integrates camera and LiDAR–inertial sensing, onboard compute, and power, without external tracking equipment or calibration of the collection environment.

A single button controls recording while an asynchronous pipeline performs parallel and batched reconstruction and publishes validated LeRobot datasets. We evaluate π0.5 and MolmoAct2 on placing six oranges in a bowl, with up to 10/10 and 8/10 successful trials, respectively. We release approximately 40 hours across three tasks and plan to release hardware designs, software, and reproduction guides at the project repository.
Hardware components

Hardware setup guide →
Exploded CAD view of the UMI-Live handheld unit, labeling the camera, ArUco tag locations, redesigned gripper fingers, removable battery module, LiDAR, LCD screen, Raspberry Pi 5, and operator-facing buttons

Human demonstrations

Small-object handling

Match lighting

Shirt folding

Recorded demonstrations

Fruit chopping

Bottle opening

Explore a LeRobot episode

Open viewer ↗

Experiments

Policy training and evaluation

MolmoAct × UMI-Live

π0.5 × UMI-Live

MolmoAct × UMI-Live

Teleoperation setup

Teleoperated orange task

Robot match-lighting task

BibTeX

@article{velamoor2026umilive,
  author  = {Velamoor, Govind and Lin, Adrian and Jung, Sam and
             Mateega, Spencer and Yang, Brandon Y. and Sethi, Amish},
  title   = {UMI-Live for In-The-Wild Bimanual Robotics Data Collection},
  year    = {2026}
}